TMIC7-28-SKF Puller Kit: Design Tutorial for Bearing Removal
Introduction: The TMIC7-28-SKF as a Design Tool
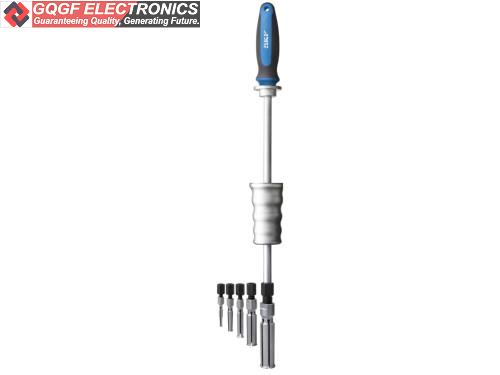
At first glance, a bearing puller kit seems out of place in an electronics tutorial. But the SKF TMIC7-28-SKF (SKU: TMIC7-28) is a precision mechanical instrument that teaches a critical lesson for hardware engineers: controlled force application and extraction are just as important on a PCB as on a motor shaft. This kit includes a crossbar, forcing screw, and nine collets (7–28 mm), designed to remove bearings without damaging shafts or housings. For this tutorial, we will design a differential current sensor circuit that monitors the motor load torque during a bearing pull—a practical application where the puller’s mechanical force translates into an electrical signal for predictive maintenance.
Design Requirements and Specifications
The circuit must measure the DC current drawn by a handheld electric puller motor (24 V, max 10 A) and output a 0–3.3 V analog signal for an ADC. Key specs:
- Supply: 5 V single rail (from USB or LDO)
- Sense range: 0–10 A with 10 mV/A sensitivity
- Bandwidth: DC to 1 kHz (to capture torque spikes during collet engagement)
- Isolation: Not required (low-side sensing on the motor return path)
- Output: Buffered, low-impedance (< 100 Ω) to drive a microcontroller ADC
Step-by-Step Design Process with Calculations
1. Select the sense element: Use a 0.01 Ω, 1% shunt resistor. At 10 A, the voltage drop is V = I × R = 10 × 0.01 = 100 mV. This is low enough to avoid ground bounce.
2. Amplifier gain: We need 3.3 V at 10 A → gain = 3.3 V / 0.1 V = 33. Use a non-inverting op-amp configuration with R1 = 1 kΩ and R2 = 32 kΩ (closest E96 value 32.4 kΩ). Gain = 1 + (32.4k/1k) = 33.4 → output at 10 A = 3.34 V (acceptable).
3. Offset nulling: At 0 A, the op-amp output should be 0 V. Use a trim pot (10 kΩ) connected to the non-inverting input via a 100 kΩ resistor to cancel input offset voltage (max ±2 mV for the op-amp, amplified by 33 → ±66 mV error).
4. Low-pass filter: Place an RC filter at the output: R = 1 kΩ, C = 0.1 µF → cutoff = 1/(2π × 1000 × 0.1e-6) = 1.59 kHz. This rejects switching noise from the motor’s PWM controller.
5. Power supply decoupling: Add 10 µF and 0.1 µF capacitors at the op-amp supply pin.
Component Selection Rationale
- Op-amp: Use the MCP6002 (dual, rail-to-rail, 1 MHz GBW). At gain 33, bandwidth = 1 MHz / 33 = 30 kHz, far above our 1 kHz requirement. Rail-to-rail output ensures 0 V to 3.3 V swing.
- Shunt: Choose a 0.01 Ω, 2 W resistor (e.g., Vishay WSL2512) to handle P = I²R = 10² × 0.01 = 1 W, with 100% derating.
- Feedback resistors: Use 1% metal film (0.1% for gain accuracy if needed). 32.4 kΩ is standard.
- Connectors: Use a 2-pin screw terminal for the motor leads, and a 3-pin header for power, ground, and output.
- PCB: 2-layer, 1 oz copper. Keep the shunt trace wide (at least 2 mm) to minimize parasitic resistance.
Simulation Tips and What to Look For
In LTspice or QSPICE, simulate the circuit with a transient analysis (0–10 ms). Drive the shunt with a current source that steps from 0 to 10 A at t=1 ms. Observe:
- Settling time: Look for the output to settle within 0.1% of 3.34 V in under 1 ms (op-amp slew rate and filter time constant).
- Overshoot: The RC filter may cause slight ringing if the source impedance is inductive—check for overshoot > 5%. Add a damping resistor (10 Ω) in series with the filter if needed.
- Offset error: Run a DC sweep from 0–10 A and measure output linearity. Expect error < 2% full scale.
Prototype Build and Testing Methodology
Build on a solderless breadboard first. Connect the TMIC7-28 puller to a small DC motor (e.g., a 24 V drill motor) with the shunt in the return line. Use a bench supply with current limiting.
1. Zero calibration: With no load, adjust the trim pot until the output reads 0.00 V.
2. Step load test: Apply a known load (e.g., clamp a spring scale to the puller screw) and record output voltage. Compare to expected V_out = 0.01 × I × 33.4.
3. Real-world test: Mount the puller on a seized bearing. Operate the forcing screw manually, while logging the output with a microcontroller. You should see a current spike as the bearing releases—this is the “breakaway torque” signature.
4. Noise check: Use an oscilloscope to verify the output is clean (ripple < 20 mV) when the motor is stalled.
Performance Verification and Optimization
Measure the transfer function using a calibrated current source (e.g., a 1 Ω precision resistor and a 10 V supply). Compute gain error and linearity. Optimize by:
- Temperature drift: The shunt’s TCR (typically ±75 ppm/°C) will dominate. For better accuracy, use a 0.01 Ω, 0.5% resistor with ±15 ppm/°C (Vishay VCS series).
- Filter tuning: If the ADC samples at 10 kHz, you can increase the filter cutoff to 3 kHz to reduce phase lag during fast torque changes.
- Grounding: Use a Kelvin connection for the shunt (separate sense traces to the op-amp) to eliminate copper trace resistance errors.
Conclusion: From Mechanical to Electrical
The TMIC7-28-SKF puller kit, when paired with this current-sense circuit, transforms a mechanical force into a quantifiable electrical signal. You’ve learned to calculate gain, select components, simulate, and verify—skills you can apply to any sensor conditioning design. The next time you pull a bearing, you’ll know exactly how much torque it took—and your circuit will be ready to prove it.