DCS16 Disc Coupling Guide: 10mm to 3/8" Shaft Applications
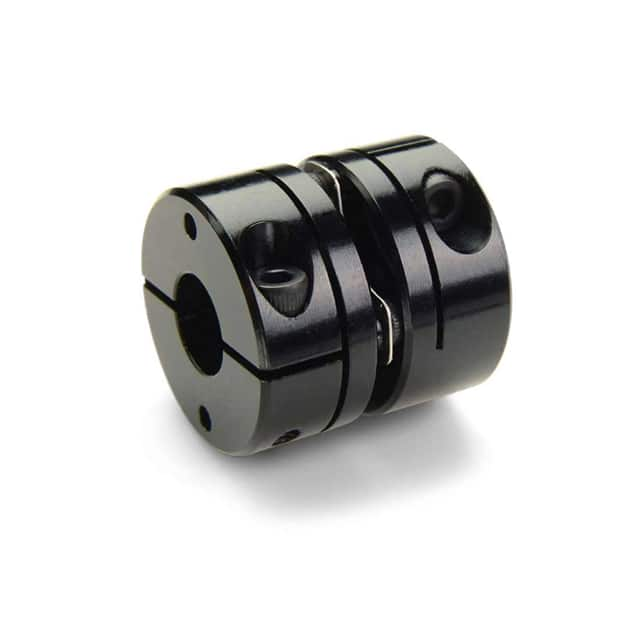
Recommended circuit topologies and design best practices: As a mechanical component, the DCS16-10MM-3/8"-A disc coupling does not participate in an electrical circuit, but rather in a mechanical power transmission loop. The “circuit” you are designing is the motion control system: a motor shaft (10 mm) driving a lead screw or encoder (3/8" inch). The best practice is to treat this coupling as a precision torque link, not a universal joint. You must ensure that the two shafts are axially aligned within the coupling’s specified parallel offset (typically 0.010" for this size) and angular misalignment (1.5° max). For servo applications, use a zero-backlash design—this Ruland disc coupling is backlash-free, but only if you torque the set screws to the manufacturer’s spec (18 in-lb for the 10 mm side, 18 in-lb for the 3/8" side) using a torque wrench. Avoid using this coupling in high-speed, high-inertia reversing applications without a keyway; the set-screw grip alone can slip under shock loads. If you must transmit higher torque, add a keyway option or use a clamp-style hub—but the DCS16-10MM-3/8"-A is a set-screw version, so design your system to limit peak torque to the rated 25 in-lb.
Component selection guidelines for supporting passives: While this coupling has no electrical passives, its mechanical “supporting components” are the shaft hubs, motor mounts, and bearing blocks. Select shafts with a minimum hardness of Rockwell C45 to prevent set-screw indentation and subsequent loss of grip. For the 10 mm motor shaft, ensure it has a flat or drilled dimple exactly where the set screw contacts—Ruland recommends a flat of at least 0.020" depth. For the 3/8" shaft (likely a lead screw or encoder input), use a shoulder or a shaft collar on both sides of the coupling to prevent axial walk. If you are using an encoder, choose a hollow-shaft encoder with a 3/8" bore and a flex mount, not a rigid mount, to avoid imposing bending loads on the coupling’s thin stainless steel discs. For the motor, select a NEMA 23 or 34 frame with a concentric pilot (not just a face mount) to guarantee initial alignment. Finally, if your system has thermal expansion, choose a coupling with a larger axial travel—this disc model allows only ±0.010" axial motion, so do not place it between two fixed bearing blocks without a sliding bearing on one end.
PCB layout recommendations and routing tips: There is no PCB in a coupling, but the adjacent electronics—motor drivers, encoder interface boards—must be laid out to avoid mechanical interference. Keep the encoder PCB at least 0.5" away from the coupling’s outer diameter to allow for a non-contact inspection tool (e.g., laser tachometer). Route motor power cables and encoder wires in separate shielded conduits, and do not route them directly under the coupling’s rotational plane—a cable tie can snag on the disc’s exposed edges. On the mechanical “board” (your machine frame), place the coupling in an accessible location for visual inspection. Provide a clearance hole in any PCB that sits above the coupling—the discs flex and expel air, so no component should sit within 1/4" vertically. For routing of the actual motion path, keep the coupling as close as possible to the driven load’s bearing to minimize torsional windup. If you must have a long shaft between the coupling and the load, use a torque-limiting shaft coupling on the far end, not a second disc coupling, to avoid over-constraining the system.
EMC/EMI considerations and mitigation strategies: This coupling is metallic and conductive, so it can act as a parasitic ground path between the motor frame and the driven machine if the shafts are not isolated. In high-noise environments (e.g., near VFDs), this can create ground loops that inject current into encoder signals. To mitigate, install an insulating shaft coupling—but this Ruland disc coupling is not insulated. Therefore, you must ensure that the motor and driven machine share a single-point ground through the chassis, not through the coupling. If you have an encoder on the driven side, add a common-mode choke on the encoder power lines and use a shielded twisted pair for A/B/Z signals, with the shield grounded at the receiver only. The coupling’s stainless steel discs do not generate EMI, but they do reflect it—so place a ferrite bead on any wire passing within 1" of the coupling’s sweep radius. In electrostatic discharge (ESD) sensitive environments, add a grounding brush that touches the coupling’s outer hub (but not the flexing discs) to bleed static charge from the belt-driven shafts.
Common design pitfalls and how to avoid them: The most frequent failure is over-tightening the set screws, which distorts the hub and causes the coupling to run out-of-round, leading to vibration and premature disc fatigue. Always use a torque wrench. Second, misalignment beyond spec will crack the thin disc packs—measure alignment with a dial indicator before final tightening, not after. Third, a common error is using this coupling on a vertical shaft without a retaining clip—the set screws can loosen under vibration, so apply thread-locking compound (blue Loctite 242) to the set screws. Fourth, do not use this coupling as a fuse to protect against overloads; it has no slip torque. Instead, add a mechanical torque limiter upstream. Fifth, designers often forget that the disc center is hollow—do not try to drill or machine it. That will destroy its balance. Finally, avoid mixing Imperial and metric hardware on the same coupling; the 10 mm bore and 3/8" bore are fine, but the set screws are metric (M6) on the 10 mm side and imperial (10-32) on the 3/8" side—use the correct Allen key (5 mm and 5/32").
Prototyping tips and bench testing procedures: On your bench, first verify bore diameters with a pin gauge—do not force the shaft in. Clean both shafts with isopropyl alcohol, then slide the coupling on, leaving a 1 mm gap between shaft ends inside the coupling. Tighten the 10 mm set screw first, then the 3/8" set screw, alternating and using a torque wrench. Mount the assembly in a lathe or V-block and measure runout with a dial indicator at the coupling’s OD—should be under 0.002" TIR. Next, run a no-load spin test at 50% of your intended max RPM for 10 minutes; check for abnormal heat using a thermocouple on the hub (should stay below 50°C). For load testing, apply a static torque via a lever arm and measure angular deflection with a laser pointer—expect less than 0.1° at rated torque. Finally, perform a reverse-direction backlash test: lock the 3/8" shaft, rotate the 10 mm shaft by hand in both directions, and use a 0.0001" dial indicator on a lever arm. Any lost motion greater than 0.0005" indicates a loose set screw or a bent disc. For long-term validation, run a 100-hour endurance test at 80% of rated torque with cyclic reversals, then inspect the discs for hairline cracks under a magnifying glass. Document all results and keep the coupling balanced with a light press-fit on the shafts—never use a hammer.