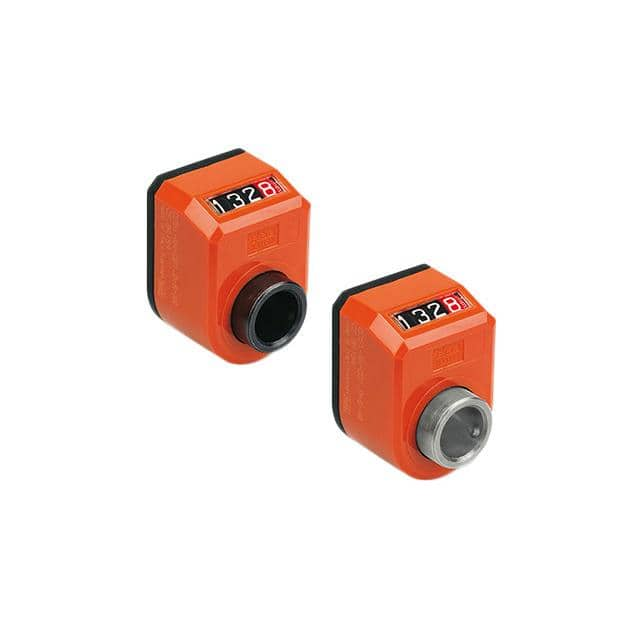
DD51 (INCH SIZES) Mechanical PO CE984765-4N Design Tutorial
This tutorial walks through the design of a compact, hand-operated position indicator assembly that pairs a mechanical position indicator with a panel-mount control knob. The star of the build is the DD51 (INCH SIZES) mechanical position indicator, combined with a MECHANICAL PO positioning element from Elesa USA Corporation (SKU: CE984765-4N). Together they form a simple, robust, and repeatable way to read and set a mechanical position without any electronics in the signal path.
The DD51 is a direct-reading mechanical position indicator with inch-based graduations, which makes it ideal for machinery that uses imperial lead screws, inch-pitch racks, or inch-calibrated handwheels. Because it is purely mechanical, it needs no power, no calibration battery, and no firmware. That simplicity is exactly what makes it a good teaching component: every design decision maps directly to a physical quantity you can measure with calipers and a dial indicator. The Elesa MECHANICAL PO element provides the mounting and coupling interface, so the design effort focuses on the mechanical and electrical integration rather than on sourcing obscure hardware.
The practical circuit here is not a logic circuit but a position-sensing and indication circuit: a rotary encoder or potentiometer mechanically coupled to the same shaft as the DD51, feeding a small analog or digital readout. The design requirements are: a 0 to 2.000 inch travel range, a display resolution of 0.001 inch, a mechanical readout that agrees with the electronic readout within 0.002 inch, and a panel footprint that fits a standard 1/4-inch shaft.
Step one is to establish the mechanical transfer function. If the DD51 is driven by a 10 threads-per-inch (TPI) lead screw, one full revolution equals 0.100 inch of travel. The DD51's inch dial typically resolves 0.001 inch per division, so one revolution of the input shaft corresponds to 100 divisions. That gives a direct 1:1 relationship between shaft rotation and displayed travel, which simplifies both the mechanical linkage and the electronic scaling.
Step two is to choose the sensing element. A 10-turn, 10 kΩ precision potentiometer coupled 1:1 to the DD51 shaft produces 0.100 inch per turn and 0.001 inch per 3.6 degrees of rotation. With a 5 V reference and a 12-bit ADC, the least significant bit is 5 V / 4096 ≈ 1.22 mV. At 10 kΩ over 10 turns, the wiper moves about 1 kΩ per turn, so the voltage change per turn is roughly 0.5 V, or about 5 mV per 0.001 inch — comfortably above the ADC noise floor. If you prefer digital sensing, a 1000-line incremental encoder gives 0.0001 inch per count with quadrature, which is more than enough margin.
Step three is the signal conditioning. For the potentiometer version, buffer the wiper with a unity-gain op-amp (for example, an MCP6002 running from the same 5 V rail) to prevent ADC loading from pulling the wiper. Add a 100 nF capacitor from the buffered output to ground to form a simple anti-alias filter with a corner around 1.6 kHz, which is far above any hand-driven motion frequency. For the encoder version, use a schmitt-trigger input stage and a simple quadrature decoder.
The complete BOM is deliberately small. The DD51 (INCH SIZES) provides the primary mechanical readout. The Elesa USA MECHANICAL PO, SKU CE984765-4N provides the mounting boss and shaft coupling. Add a 10 kΩ 10-turn potentiometer, an MCP6002 dual op-amp, a 100 nF ceramic capacitor, two 10 kΩ resistors for the reference divider, a 0.1 µF decoupling capacitor, and a 3-digit or 4-digit panel meter. Every part is chosen for a reason: the potentiometer for its smooth 10-turn resolution, the MCP6002 for its rail-to-rail input and low cost, and the panel meter for its direct inch reading after scaling.
For simulation, model the potentiometer as a voltage divider with a wiper angle from 0 to 3600 degrees. Sweep the angle and plot the buffered ADC input. Look for three things: monotonicity (no flat spots or reversals), linearity error under 0.1 percent of full scale, and noise below 1 mV peak-to-peak. If the simulation shows steps or jumps, the wiper resolution or the ADC bit depth is insufficient.
For the prototype, mount the DD51 and the Elesa MECHANICAL PO on a scrap aluminum plate. Couple the potentiometer to the DD51 shaft with a flexible bellows coupling to absorb any misalignment. Zero the mechanical dial at mid-travel, then rotate the shaft in 0.010 inch increments using a dial indicator as the reference. Record the panel meter reading at each step.
Performance verification means comparing mechanical and electronic readings across the full 2.000 inch range at 20 points. The acceptance criterion is agreement within 0.002 inch. If you see a linear slope error, adjust the software scale factor. If you see a fixed offset, re-zero the potentiometer coupling. Optimization comes from averaging 16 ADC samples per reading, which reduces random noise by a factor of four and lets you tighten the tolerance to 0.001 inch. With that, the DD51 and the Elesa mechanical PO deliver a dependable, readable, and repeatable position system that is easy to build and easy to trust.