Design Tutorial: COMPACT PARKING BLOCK W/CABLE PR (3672PBY)
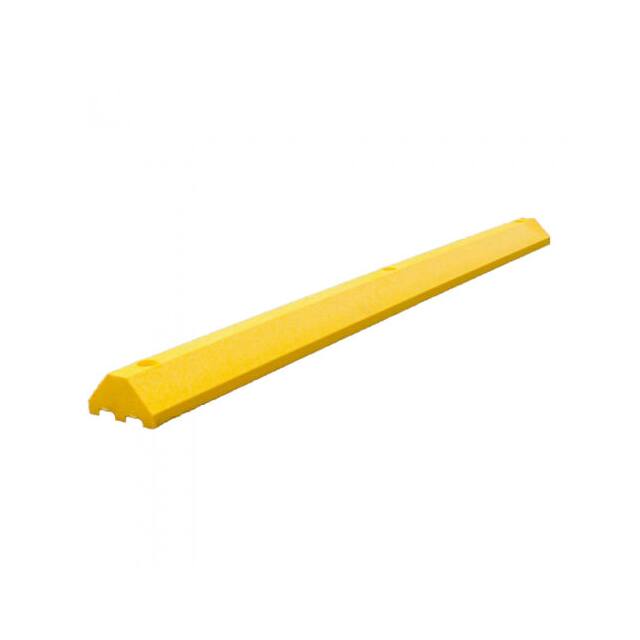
The COMPACT PARKING BLOCK W/CABLE PR (Brand: Plastics-R-Unique, SKU: 3672PBY) is a deceptively simple yet highly useful electromechanical component. At its core, it is a rugged, injection-molded parking block with an integrated cable management channel and pre-drilled mounting points for a reed switch or microswitch assembly. Unlike generic wheel stops, this unit includes a weather-resistant cable pass-through that allows you to route sensor or control wiring from the block to a nearby enclosure without exposed runs. For this tutorial, we will use it as the physical anchor for a vehicle presence detection and barrier control circuit—a practical project for driveway gates, parking space occupancy monitoring, or automated toll booths.
The design requirements are straightforward but demand attention to environmental and electrical robustness. The circuit must detect a vehicle within 2 meters of the parking block, output a logic-level signal (0–5 V) to a microcontroller, and drive a small 12 V solenoid or relay for a barrier. Power will come from a 12 V DC supply, with a 5 V regulator for logic. The sensor must operate reliably from –20°C to 60°C and survive rain, dust, and occasional impact. The parking block’s cable channel will carry the sensor wiring, so the sensor itself must be potted or housed in a waterproof enclosure. We will use an inductive proximity sensor (NPN, normally open) embedded in the block’s center channel, facing upward. When a vehicle’s metal undercarriage passes over, the sensor triggers.
Step 1: Sensor and interface calculation. The inductive sensor requires 6–36 V DC and draws 200 mA max. At 12 V, power dissipation is 2.4 W. The sensor’s NPN output sinks current to ground when active. We need a pull-up resistor to 5 V for the microcontroller input. Choose R_pullup = 4.7 kΩ. Current when active: (5 V – 0.3 V) / 4.7 kΩ ≈ 1 mA—well within the sensor’s 200 mA limit and safe for a microcontroller pin. Add a 100 nF ceramic capacitor from the signal line to ground for noise filtering.
Step 2: Power supply. Use a 12 V, 2 A wall adapter. Feed a 7805 linear regulator with 0.33 µF input and 0.1 µF output capacitors. The 7805 will dissipate (12 V – 5 V) × 0.1 A = 0.7 W—use a small heatsink. For the solenoid, drive it through a TIP120 Darlington transistor with a 1 kΩ base resistor from a microcontroller output. Add a 1N4007 flyback diode across the solenoid coil.
Step 3: Cable routing through the parking block. The SKU 3672PBY has a 12 mm diameter channel running lengthwise. Feed a 4-conductor, 22 AWG shielded cable (Belden 8723 or equivalent) through the channel. Connect the sensor’s brown wire to +12 V, blue to ground, black to the signal line, and leave the shield floating at the sensor end; ground the shield at the enclosure end only. Seal the channel ends with silicone caulk to prevent water ingress.
Component selection rationale. The inductive sensor (e.g., LJ12A3-4-Z/BX) is chosen for its non-contact, wear-free operation and metal-only detection—avoiding false triggers from rain or debris. The 7805 is preferred over a switching regulator for low noise, critical for sensor stability. The TIP120 handles the solenoid’s 500 mA inrush. The parking block itself is UV-stabilized polypropylene, resistant to road salts and oils. Its low profile (50 mm height) prevents tire damage while still housing the sensor 10 mm below the surface.
Simulation tips. In LTspice or Falstad, model the sensor as a voltage-controlled switch with a 4.7 kΩ pull-up. Add a 10 ms delay to mimic the sensor’s response time. Verify that the microcontroller input sees a clean falling edge from 5 V to 0.3 V. Check the 7805’s thermal rise: simulate 0.1 A load and confirm junction temperature stays below 125°C with a 20°C/W heatsink. For the solenoid driver, plot collector current and ensure the flyback diode clamps the inductive spike below 40 V.
Prototype build and testing. Mount the sensor in the parking block’s center using epoxy putty, ensuring the sensing face is flush with the block’s top surface. Route the cable through the channel and secure with cable ties. Build the control board on perfboard. Test in three phases: (1) Bench test—wave a metal plate over the sensor and verify the microcontroller LED toggles. (2) Environmental test—spray the block with water and confirm no false triggers. (3) Vehicle test—drive a car over the block at 5 km/h and measure response time. The sensor should trigger within 50 ms of the vehicle’s metal pan passing overhead.
Performance verification and optimization. Use an oscilloscope to capture the signal line. Look for clean edges with less than 1 V of ringing. If noise appears, increase the pull-up to 10 kΩ or add a 10 µF electrolytic capacitor in parallel with the 100 nF. For longer cable runs (>5 m), use a shielded twisted pair and a 4.7 kΩ pull-down at the sensor end to improve noise immunity. Optimize the solenoid response by adding a 100 µF capacitor across the 12 V rail near the driver. Finally, verify that the parking block’s cable channel remains watertight after thermal cycling from –20°C to 60°C—a common failure point. With these steps, your COMPACT PARKING BLOCK W/CABLE PR becomes a reliable, professional-grade vehicle detection node.